Useless Project 3.0 — Our Build Journey

Servo Naatyam

We had an idea, a bunch of components, and absolutely no idea how the night was going to go.

1 Night
6 Figures Made
0 Hrs Sleep

The Full Story, In Order

From first idea to final tape fix — everything, honestly.

Before 6 PM
💡 The Idea Sparks
Watching Thiruvathira at college. What if we recreated this with hardware?
Pre-Hackathon
🔧 Gathering Components
EC friend, IEDC club, two personally bought servo motors.
6:00 PM
🚀 Hackathon Begins
Also handling campus lead responsibilities simultaneously.
STARTED
Evening
✂️ Making Six Figures
Printed Thiruvathira dancers, attached to thick board, cut to shape.
Late Evening
😬 The Cutting Nightmare
Thick board, difficult cutting. A small hand cut. One leg accidentally cut off.
INCIDENT
Night
✅ All Servos Working
All servos tested and confirmed rotating. Brief moment of hope.
ALL MOVING
Night
🔫 The Glue Incident
Glue gun borrowed. Glue enters three servo gears. Three motors jammed.
3 JAMMED
Early Morning
🌅 Pookalam + Debugging Begins
Flowers arranged. Then the working servos also stopped. Rebuilding from scratch.
DEBUGGING
7:00 AM
😴 Nothing Moving
Zero servos responding. Exhaustion peak. One accidental nap on the table.
0 / 6 MOVING
Morning
☕ Breakfast + One More Try
Wiring redone from scratch. Code reworked. Individual motor tests.
REBUILDING
Final Stage
🎉 3 Servos Alive
Three figures moving. Masking tape reinforcements. Imperfect, but alive.
3 / 6 MOVING

The Idea

The idea for Servo Naatyam came quite unexpectedly.

We were watching a Thiruvathira performance at our college when I suddenly had an idea — what if we recreated something inspired by Thiruvathira using hardware?

Hardware was completely new territory for me. I had never really worked with hardware before, so I didn't even know what components we needed or how to put everything together.

I started asking friends who had some experience with hardware. One of my friends from the EC department helped me arrange some of the components, and we also managed to collect a few more through our IEDC club. I also bought two servo motors myself.

And somehow, we had enough components to begin.
⚠️ Hardware experience: Basically new territory
Friend from EC department helped arrange components
Additional components collected via IEDC club
Two servo motors personally purchased
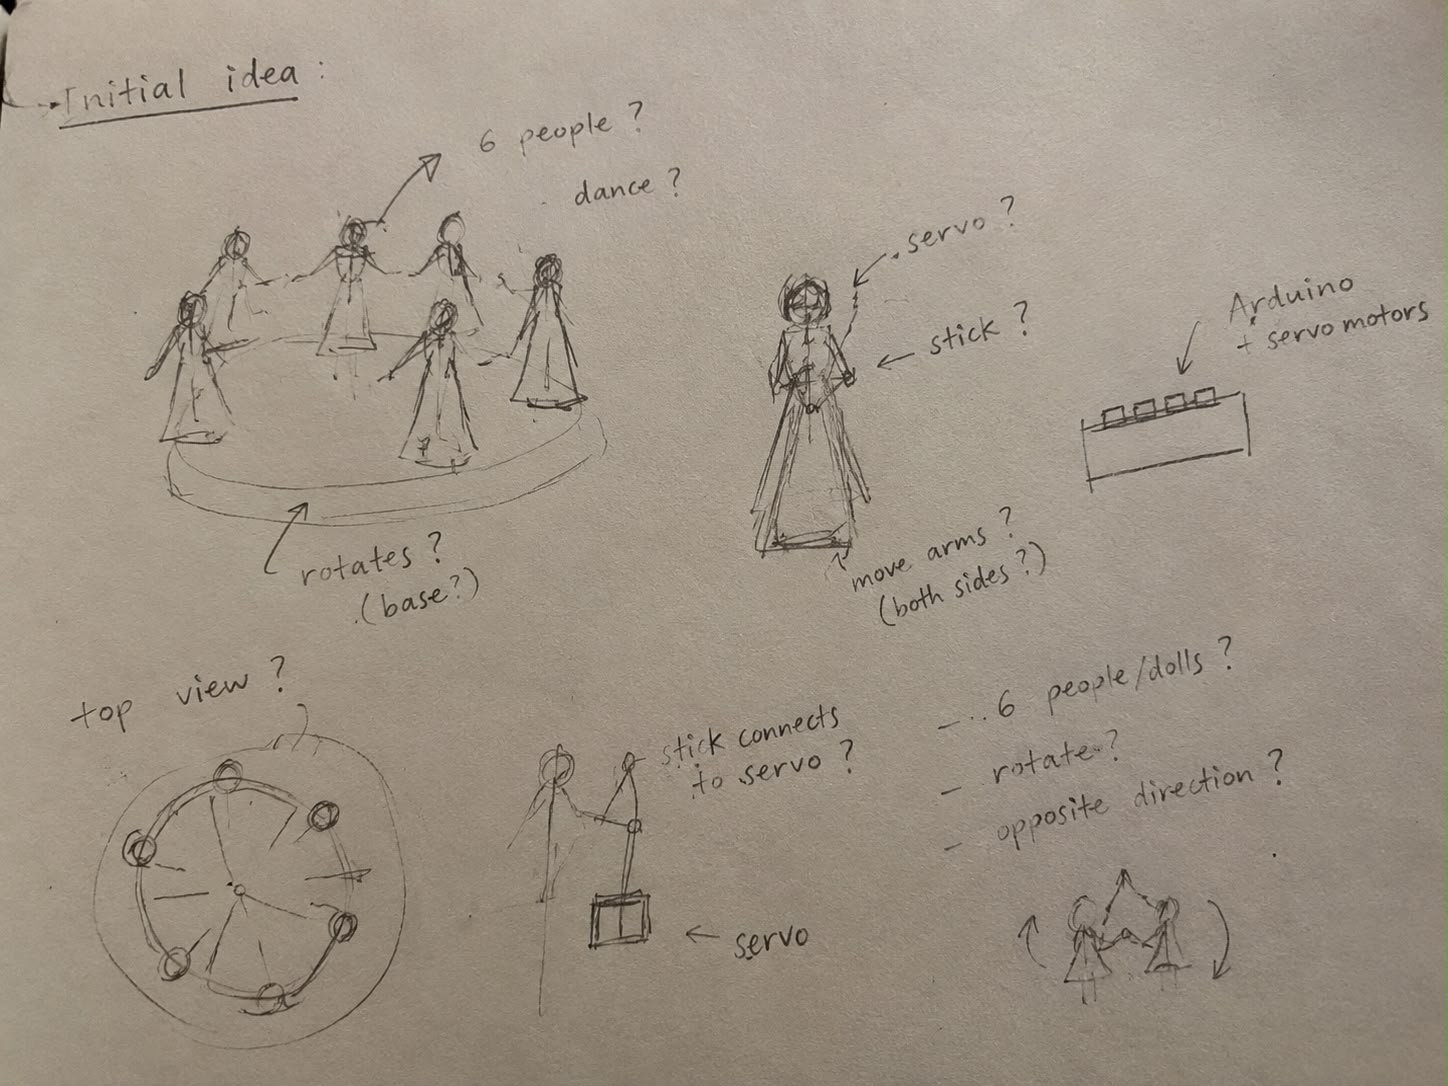
Initial idea sketch showing six figures and servo layout
Initial idea sketch — six figures, servo layout
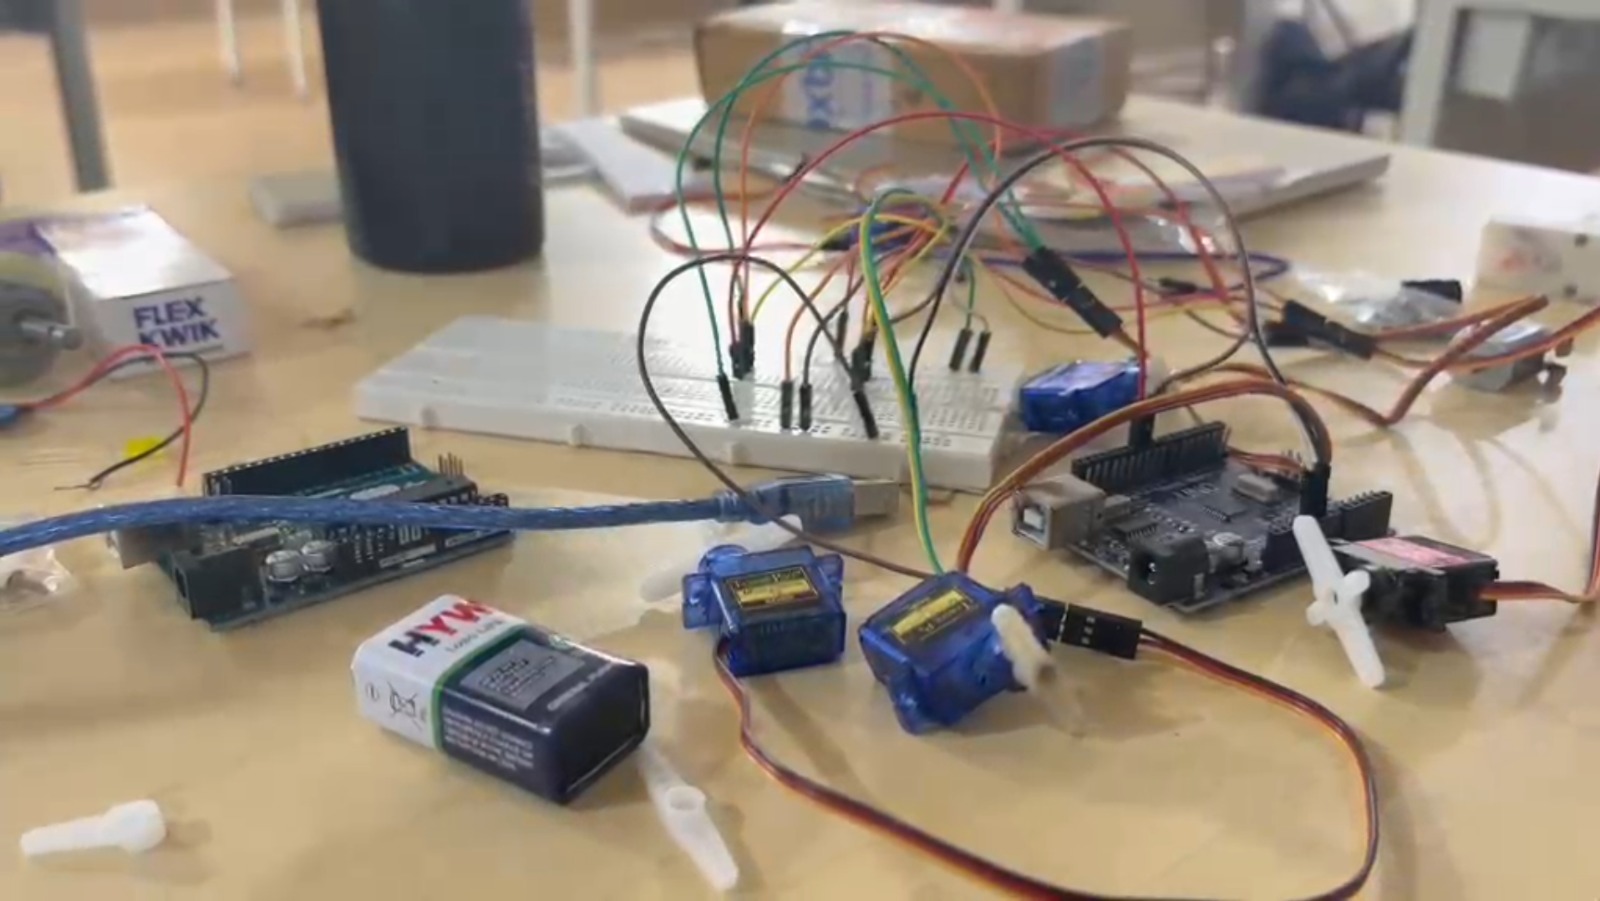
Arduino, servo motors and breadboard laid out on a table
Components — Arduino, Servos, Breadboard
Video — Components setup & hardware testing

6:00 PM — The Hackathon Begins

The hackathon started at 6 PM. Since I was also involved as a campus lead, I had responsibilities to manage alongside the project. So while handling those responsibilities, I was also trying to somehow get our project started.

Eventually, we sat down and began building.

Our first major task was creating the six Thiruvathira figures. We had printed pictures of Thiruvathira dancers and planned to stick them onto a thick board, cut them into shape, and eventually attach them to the servo motors.

Video — Sticking Thiruvathira dancer prints to the board
Sounds simple. It wasn't.

The Cutting Nightmare

Cutting the thick board turned out to be one of the most time-consuming parts of the entire project.

The board was surprisingly difficult to cut, and we had to carefully follow the shapes of the printed figures. My teammate even ended up getting a small cut on their hand while working on it.

Between the two of us, we slowly cut out all six figures and stuck the printed images onto them.

And somewhere in the middle of all that cutting, I accidentally cut off part of one of the figure's legs.

At that point, there was no time to start over. We simply put the pieces back together, stuck them in place and continued.

By the time we finally finished making all six figures, it was already getting close to morning.

Video — Hand-cutting the thick board figures

Damage Report

Figures completed6 / 6
Accidental casualties1 leg
Hand cuts sustained1 (teammate)
ResolutionTaped + continued

Food, Chaos and Back to Work

In between all of this, we took breaks to eat and joined in some of the other activities happening during the hackathon.

But eventually, it was time to come back to the project. Now came the part we were actually excited about — making the figures move.

We started testing the servo motors one by one. We wrote the code, connected the servos to the breadboard and Arduino, and tested each motor individually.

And surprisingly…

They all worked. Every servo was rotating.

For a moment, everything seemed to be going exactly according to plan.

Video — Team working together during the overnight build
6 / 6
SERVOS WORKING

The Glue Problem

The next step was to attach each of our handmade figures to the top of a servo motor.

We tried using the glue we had, but it wasn't holding properly. Luckily, another team had a glue gun. So we borrowed it and started attaching the figures to the servos one by one.

And then…

Three of the servo motors stopped working.

Some of the glue had entered the gears inside the servo motors and jammed them. The motors that we had already tested and confirmed were working were now physically stuck.

We had lost three servo motors because of the glue. And by then, it was already getting very late.

HOW IT HAPPENED — MECHANICAL FAILURE

🔫 Glue Gun
→
Entered Internal Gears
→
Glue Hardened
→
⚙️ Gears Jammed
→
🔴 Motor Unusable

The servos were mechanically jammed — not electrically damaged. Glue blocked the gear mechanism inside the housing.

Morning — And Everything Broke

As morning approached, we went out and bought flowers for the pookalam. We came back, arranged the flowers, glued them onto the board, and started putting everything together.

This was supposed to be the final stage.

Except…

When we checked the servo motors again, the ones that had been working earlier were suddenly not rotating anymore.

We had no idea what had happened. So we started debugging — disconnecting everything, checking each wire, reworking the code, and testing again. Over and over.

7:00 AM — Nothing Worked

By around 7 AM, things had gone from bad to worse. None of the servos were working. After staying awake through the entire night, watching the project slowly fall apart was honestly devastating.

We were exhausted. We had spent hours cutting, sticking, wiring and testing everything, and now it felt like we were back at zero.

At some point, I was so tired that I ended up lying down on the table and accidentally falling asleep there. Just for a while.

0 / 6 MOVING
completely stuck. every motor silent.

One More Try

After waking up, we had breakfast and came back to the project. We decided to start again from the beginning.

All the connections were removed. Everything was checked again. The wiring was redone. The code was reworked. We tested the motors individually.

And finally, something started working again.

Not everything. But something.

Three Motors

After all the debugging, we managed to get three servo motors working. The other three stayed still.

It wasn't what we had originally imagined. We had started with the idea of having all six figures moving, but after everything that had happened during the night, even getting three of them to move felt like a small victory.

And then we had another problem. The figures we had glued onto the servo motors had started becoming loose. So we grabbed masking tape and started reinforcing and adjusting them.

It wasn't perfect. It wasn't even close to what we had originally imagined. But somehow…

we managed it.

3 / 6
SERVO MOTORS MOVING  ·  3 STATIONARY (GLUE-JAMMED)
Video — Servo Naatyam in motion! Three figures dancing
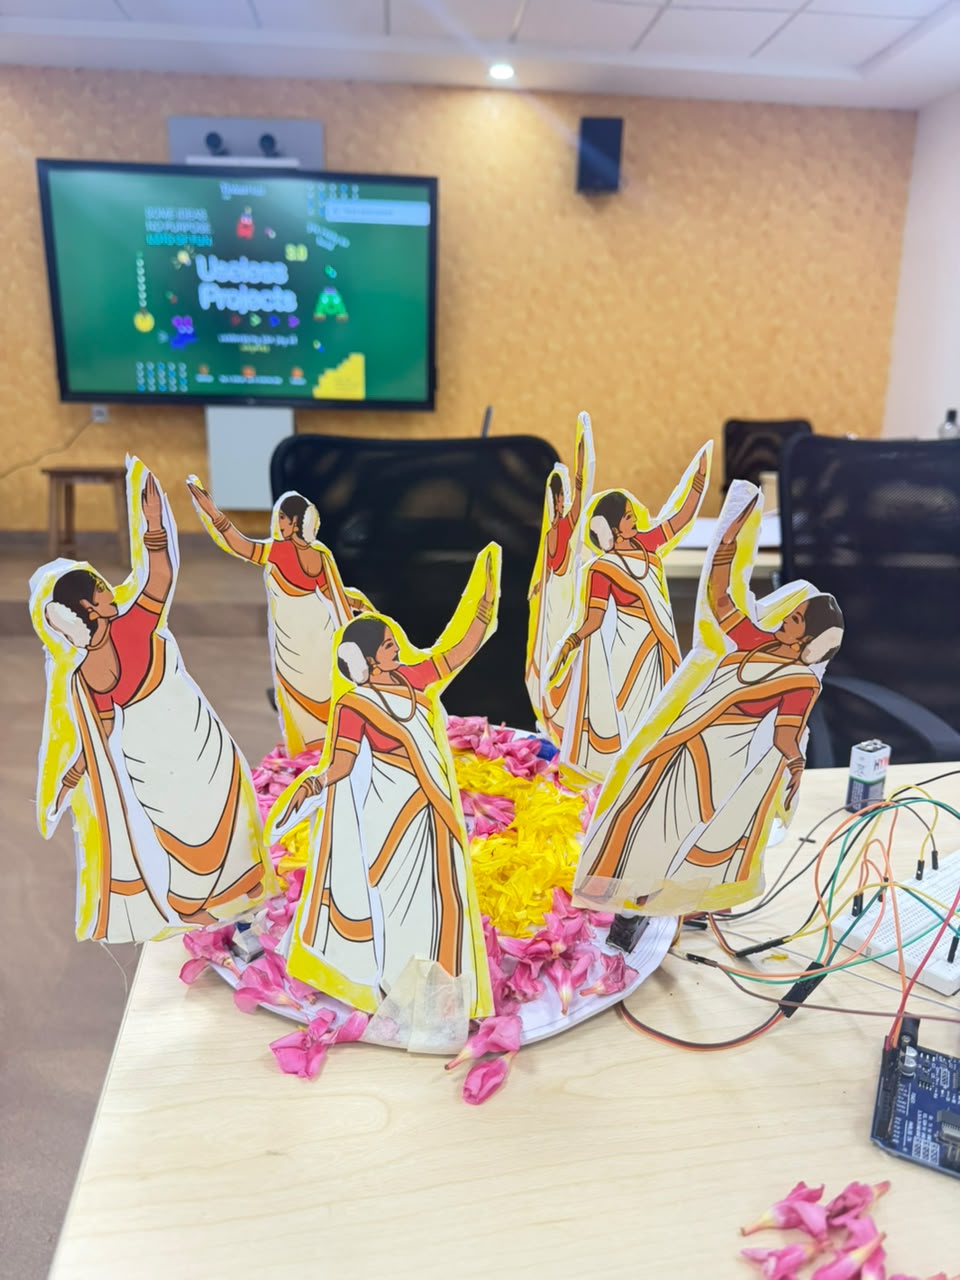
The finished Servo Naatyam project — six Thiruvathira figures arranged around a pookalam with Arduino and wires visible
The finished project — six figures, flower pookalam, and the Arduino setup

What Actually Went Wrong?

A factual account of the failures — no exaggeration, nothing invented.

01
✂️ Cutting the Figures
The thick board was difficult to cut and required careful tracing of the figure shapes. One figure's leg was accidentally cut off during this process and had to be reattached in place.
02
🔫 Glue Entered the Servo Gears
Three servo motors stopped working because glue from the glue gun entered their internal gear mechanisms and hardened, physically jamming the motors. This was a mechanical failure — not electrical. The three motors could not be recovered.
03
🔌 Wiring and Testing
The remaining setup required repeated disconnecting, checking, reconnecting, and testing before the servos responded correctly again. Code was changed multiple times. The process was repeated more times than we could count.
04
📎 Mechanical Attachment
The handmade figures became loose after being attached to the servo motors. Masking tape was used to reinforce and stabilise the attachment.
05
😴 Time and Exhaustion
The project continued through the entire night. By morning, exhaustion had become a significant challenge. At least one team member accidentally fell asleep at the table during the debugging phase.

What We Learned

🔧
Hardware is very different from software
Hardware was new territory for us, so we learned by physically experimenting with components rather than knowing everything beforehand. You can't just revert a commit.
🧪
Test before permanently attaching things
We learned the hard way that components should be secured carefully without interfering with their moving parts. Always test in place before using any adhesive.
⚙️
Mechanical problems matter
Even if the Arduino code is working, the physical construction can still stop the project from working. Software correctness doesn't guarantee hardware success.
🔄
Debugging means starting again
Sometimes the fastest way forward is to disconnect everything and rebuild the setup step by step. Incremental debugging on a messy wiring setup doesn't always work.
🔫
Components can fail because of physical construction
The glue incident showed us that even something as simple as attaching a figure can affect the internal mechanism of a servo. Handle moving components carefully.
🎲
Hackathons are unpredictable
A project can go from fully working to barely functional very quickly. Plan for things to go wrong. They will.
🏆
Small victories count
Getting three figures moving after an overnight build still felt like a win. After everything the night threw at us, that was enough to make us smile.

Final Reflection

We started with an idea inspired by a Thiruvathira performance.

Hardware was completely new territory for us.

We figured things out as we went.

We cut six figures, lost three servo motors when glue entered their gears and jammed them, watched the remaining setup stop working, rebuilt our wiring, debugged through the morning, and finally got three figures moving again.

It wasn't the perfect version we imagined at the beginning.

But it was something we built ourselves.

And after one very long night, that was enough.